Machine Vision industrial solution
Home/Solutions/Machine Vision
02 / See quality at production speed

Machine vision.
Inspect at production speed.

THE MXPAC APPROACH

Machine Vision

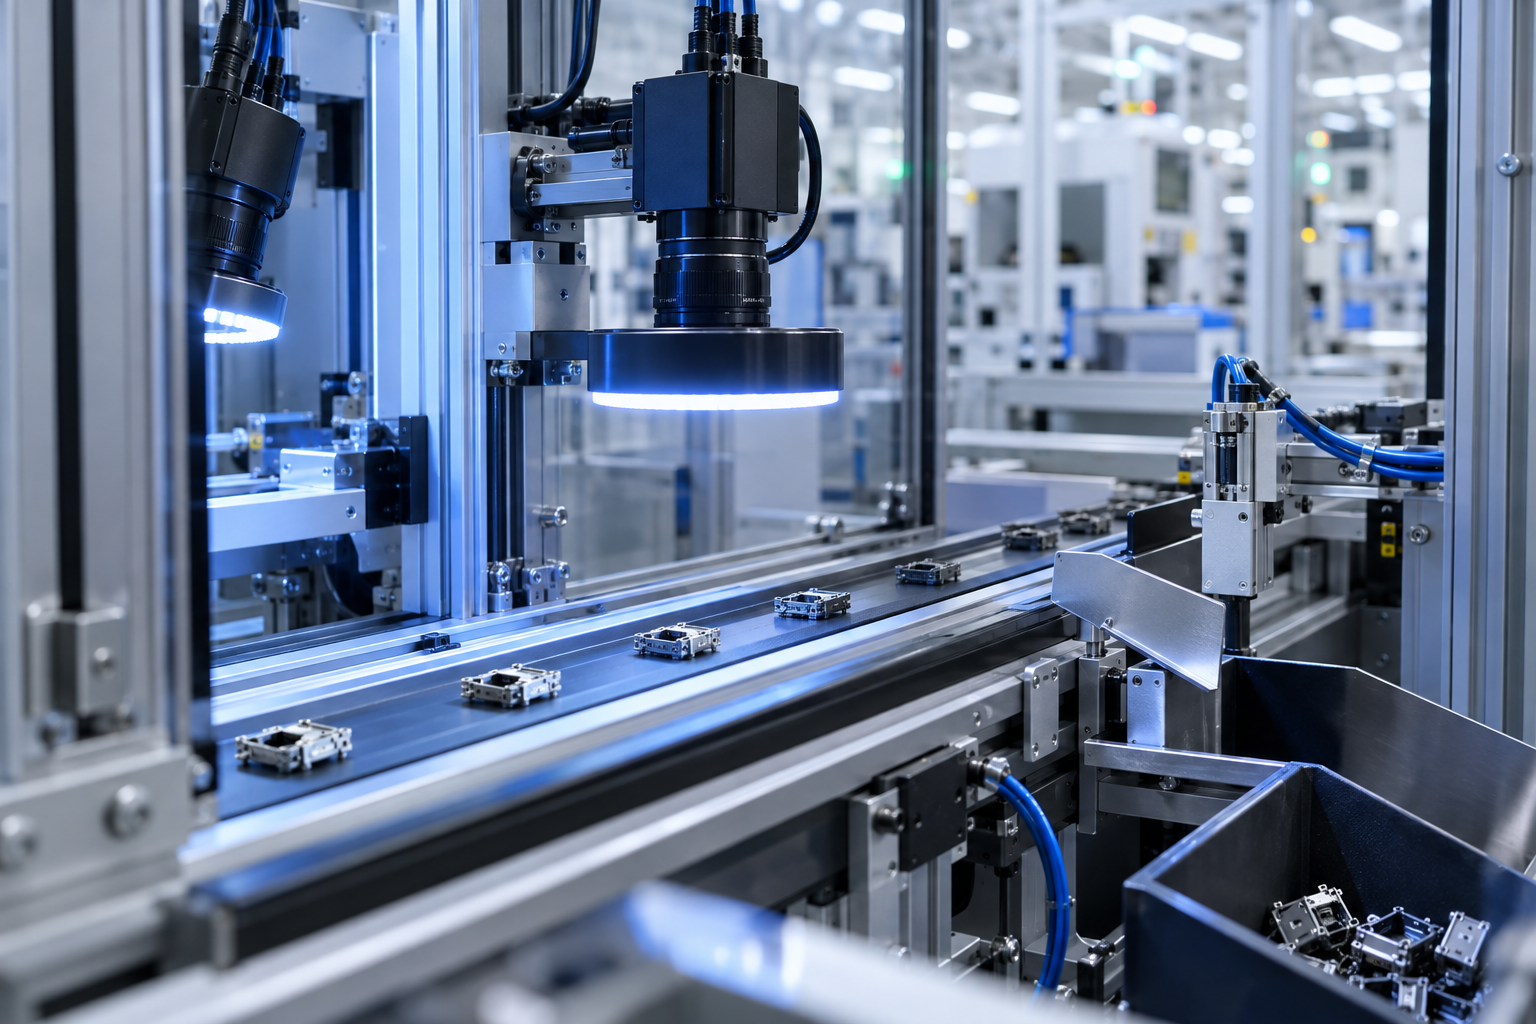
MXPAC in Penang, Malaysia turns your visual acceptance criteria into controlled lighting, optics, inspection logic and production action.

DESIGNED OUTCOMEConsistent inspection at line speed, with clear pass/fail action and data that supports root-cause work.

WHEN THIS SOLUTION FITS

Start with the constraint,
not the equipment.

01

Subjective manual inspection

02

Defects found too late in the process

03

Missing parts, wrong orientation or mix-up

04

Measurements that are slow or inconsistent

WHAT WE PROVIDE

A connected scope
from concept to support.

  1. Feasibility study and sample evaluation
  2. Camera, lens and lighting selection
  3. Inspection algorithm and recipe design
  4. Reject handling and machine integration
  5. Result logging and traceability connection
TYPICAL APPLICATIONS
Presence / absenceSurface defectDimension checkOCR / code readingPosition guidanceAssembly verification
SAMPLE USE CASES

See where the solution
fits into production.

These examples show deployment points, typical system components and the operating result. Final equipment selection follows the site, range, environment and interface study.

Example deployment for Machine Vision
DEPLOYMENT VIEWDevice + process + controls + data
01

Label and code verification

WHEREImmediately after printing or labelling

SYSTEMCamera, controlled light, trigger sensor, encoder and reject mechanism

FLOWDetect product → capture code → verify content and readability → reject mismatch

Prevents wrong or unreadable labels from reaching the next process.
02

Assembly completeness check

WHEREAt the final station of a manual or automated assembly line

SYSTEMTop and side cameras, fixture sensor, inspection recipe and operator display

FLOWLoad assembly → confirm position → inspect components → record pass/fail image

Finds missing, reversed or incorrectly seated parts at source.
03

Robot guidance

WHEREAbove a conveyor, tray or random-part presentation area

SYSTEMVision camera, calibration target, robot interface and position correction

FLOWLocate part → calculate position → send coordinates → robot picks accurately

Allows flexible part presentation with less reliance on hard tooling.
PROJECT FLOW
01Discover

Process observation, samples, constraints and success criteria.

02Engineer

Concept, risk review, controls and integration details.

03Validate

Build, testing and acceptance against the agreed intent.

04Deploy

Installation, training, handover and support planning.

START A CONVERSATION

Let’s review your
process challenge.

Tell us what the process needs to achieve. We will help define the practical engineering questions first.

Start a project ↗